Bringup - Nav2
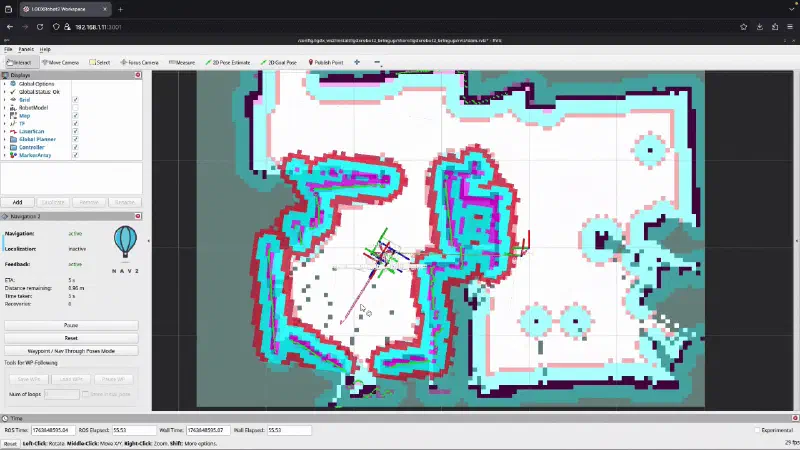
The nav launch file is used to start the Nav2 stack by initialising the required hardware and displaying it in RViz2.
Examples
SLAM on Nav2
ros2 launch lgdxrobot2_bringup nav_launch.py \
  slam:=True \
  profile:='slam' \
  use_rviz:=True
SLAM on Nav2 using JOY
ros2 launch lgdxrobot2_bringup nav_launch.py \
  slam:=True \
  profile:='slam' \
  use_joy:=True \
  use_rviz:=True
SLAM on Nav2 using teleop_twist_keyboard
Terminal 1:
ros2 launch lgdxrobot2_bringup nav_launch.py \
  slam:=True \
  profile:='slam' \
  use_keyboard:=True \
  use_rviz:=True
Terminal 2:
ros2 run teleop_twist_keyboard teleop_twist_keyboard \
  --ros-args --remap /cmd_vel:=/keyboard
Localisation on Nav2
ros2 launch lgdxrobot2_bringup nav_launch.py \
  map:=<Absolute path to the map yaml file> \
  use_rviz:=True
Localisation on Nav2 using other controller plugin
ros2 launch lgdxrobot2_bringup nav_launch.py \
  map:=<Absolute path to the map yaml file> \
  profile:='loc-mppi' \
  use_rviz:=True
Parameters
| Parameter | Type | Description |
|---|---|---|
| profiles_path | string | bsolute path to the profiles directory, or leave empty to use the default. |
| profile | string | Parameters profile. |
| namespace | string | Namespace for the robot. |
| slam | bool | Whether to run a SLAM. |
| use_localization | bool | Whether to enable localization or not. |
| map | string | Absolute path to the map YAML file. |
| keepout_mask | string | Full path to keepout mask yaml file to load. |
| speed_mask | string | Full path to speed mask yaml file to load. |
| graph | string | Path to the graph file to load. |
| autostart | bool | Automatically start up the Nav2 stack. |
| use_composition | bool | Whether to use composed bringup. |
| use_intra_process_comms | bool | Whether to use intra process communications |
| container_name | string | the name of container that nodes will load in if use composition is true. |
| use_respawn | bool | Whether to respawn if a node crashes. |
| use_keepout_zones | bool | Whether to enable keepout zones or not. |
| use_speed_zones | bool | Whether to enable speed zones or not. |
| log_level | string | Log level. |
| use_rviz | bool | Launch RViz2. |
| rviz_config | string | Absolute path for the RViz config file. |
| use_joy | bool | Whether to enable the joy. |
| use_keyboard | bool | Control the robot using teleop_twist_keyboard. Start the node in another terminal to control the robot. |
| Parameter | Type | Description |
|---|---|---|
| profiles_path | string | bsolute path to the profiles directory, or leave empty to use the default. |
| profile | string | Parameters profile. |
| namespace | string | Namespace for the robot. |
| slam | bool | Whether to run a SLAM. |
| use_localization | bool | Whether to enable localization or not. |
| map | string | Absolute path to the map YAML file. |
| autostart | bool | Automatically start up the Nav2 stack. |
| use_composition | bool | Whether to use composed bringup. |
| use_respawn | bool | Whether to respawn if a node crashes. |
| use_rviz | bool | Launch RViz2. |
| rviz_config | string | Absolute path for the RViz config file. |
| use_joy | bool | Whether to enable the joy. |
| use_keyboard | bool | Control the robot using teleop_twist_keyboard. Start the node in another terminal to control the robot. |